SCARA Robotic Arm Project
Modelling and controlling a SCARA robotic arm.
I defined the reference frames with the Denavit-Hartenberg method for the forward kinematics, then derived the geometric equations for the inverse. The existing code had to be extended there, because θ₂ has more than one valid solution and it only handled one.
The Jacobian turned end-effector velocities into joint velocities. I also added two trajectory modes, linear and circular, both correcting for deviation along the way.
The project was done in a custom simulator, created by my professor at the time, so I don’t have any pictures of it working. Here is one of a SCARA robot to give more context: 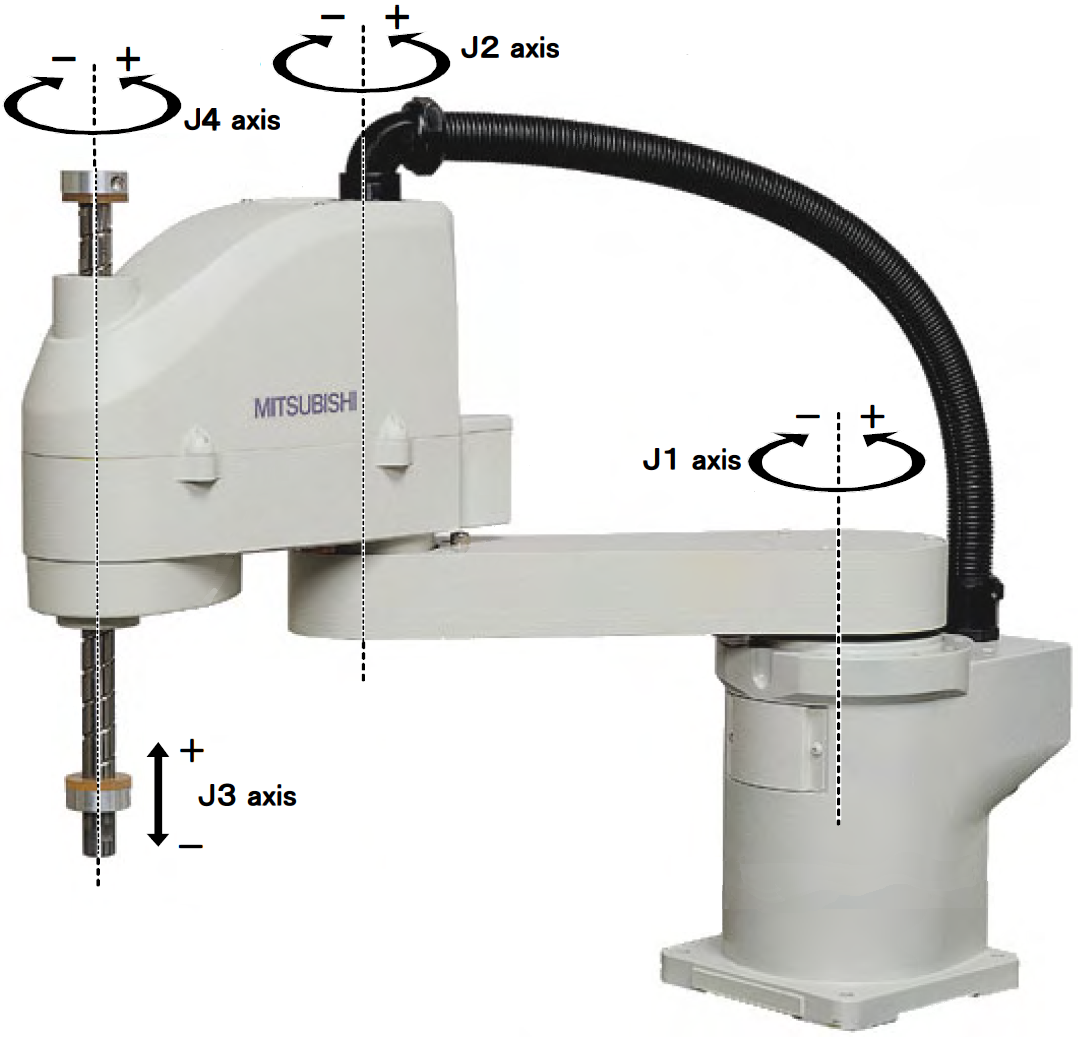
Highlights
- Working with Robotics topics is fun.
- Having to think in 3 dimensions is satisfying. I wish I had taken up technical drawing. I should learn it and CAD as well (although I’ve had some exploration time with it).
Lowlights
- Working with a custom simulator came with some “lack of documentation” problems.
Lessons Learned
- It’s ok to ask stupid questions. I had totally forgotten what the “Inner Product” was and sent an email to my Professor, who answered me in person. He made me understand I was being a dummy, but in a kind way. I’ve had worse responses.